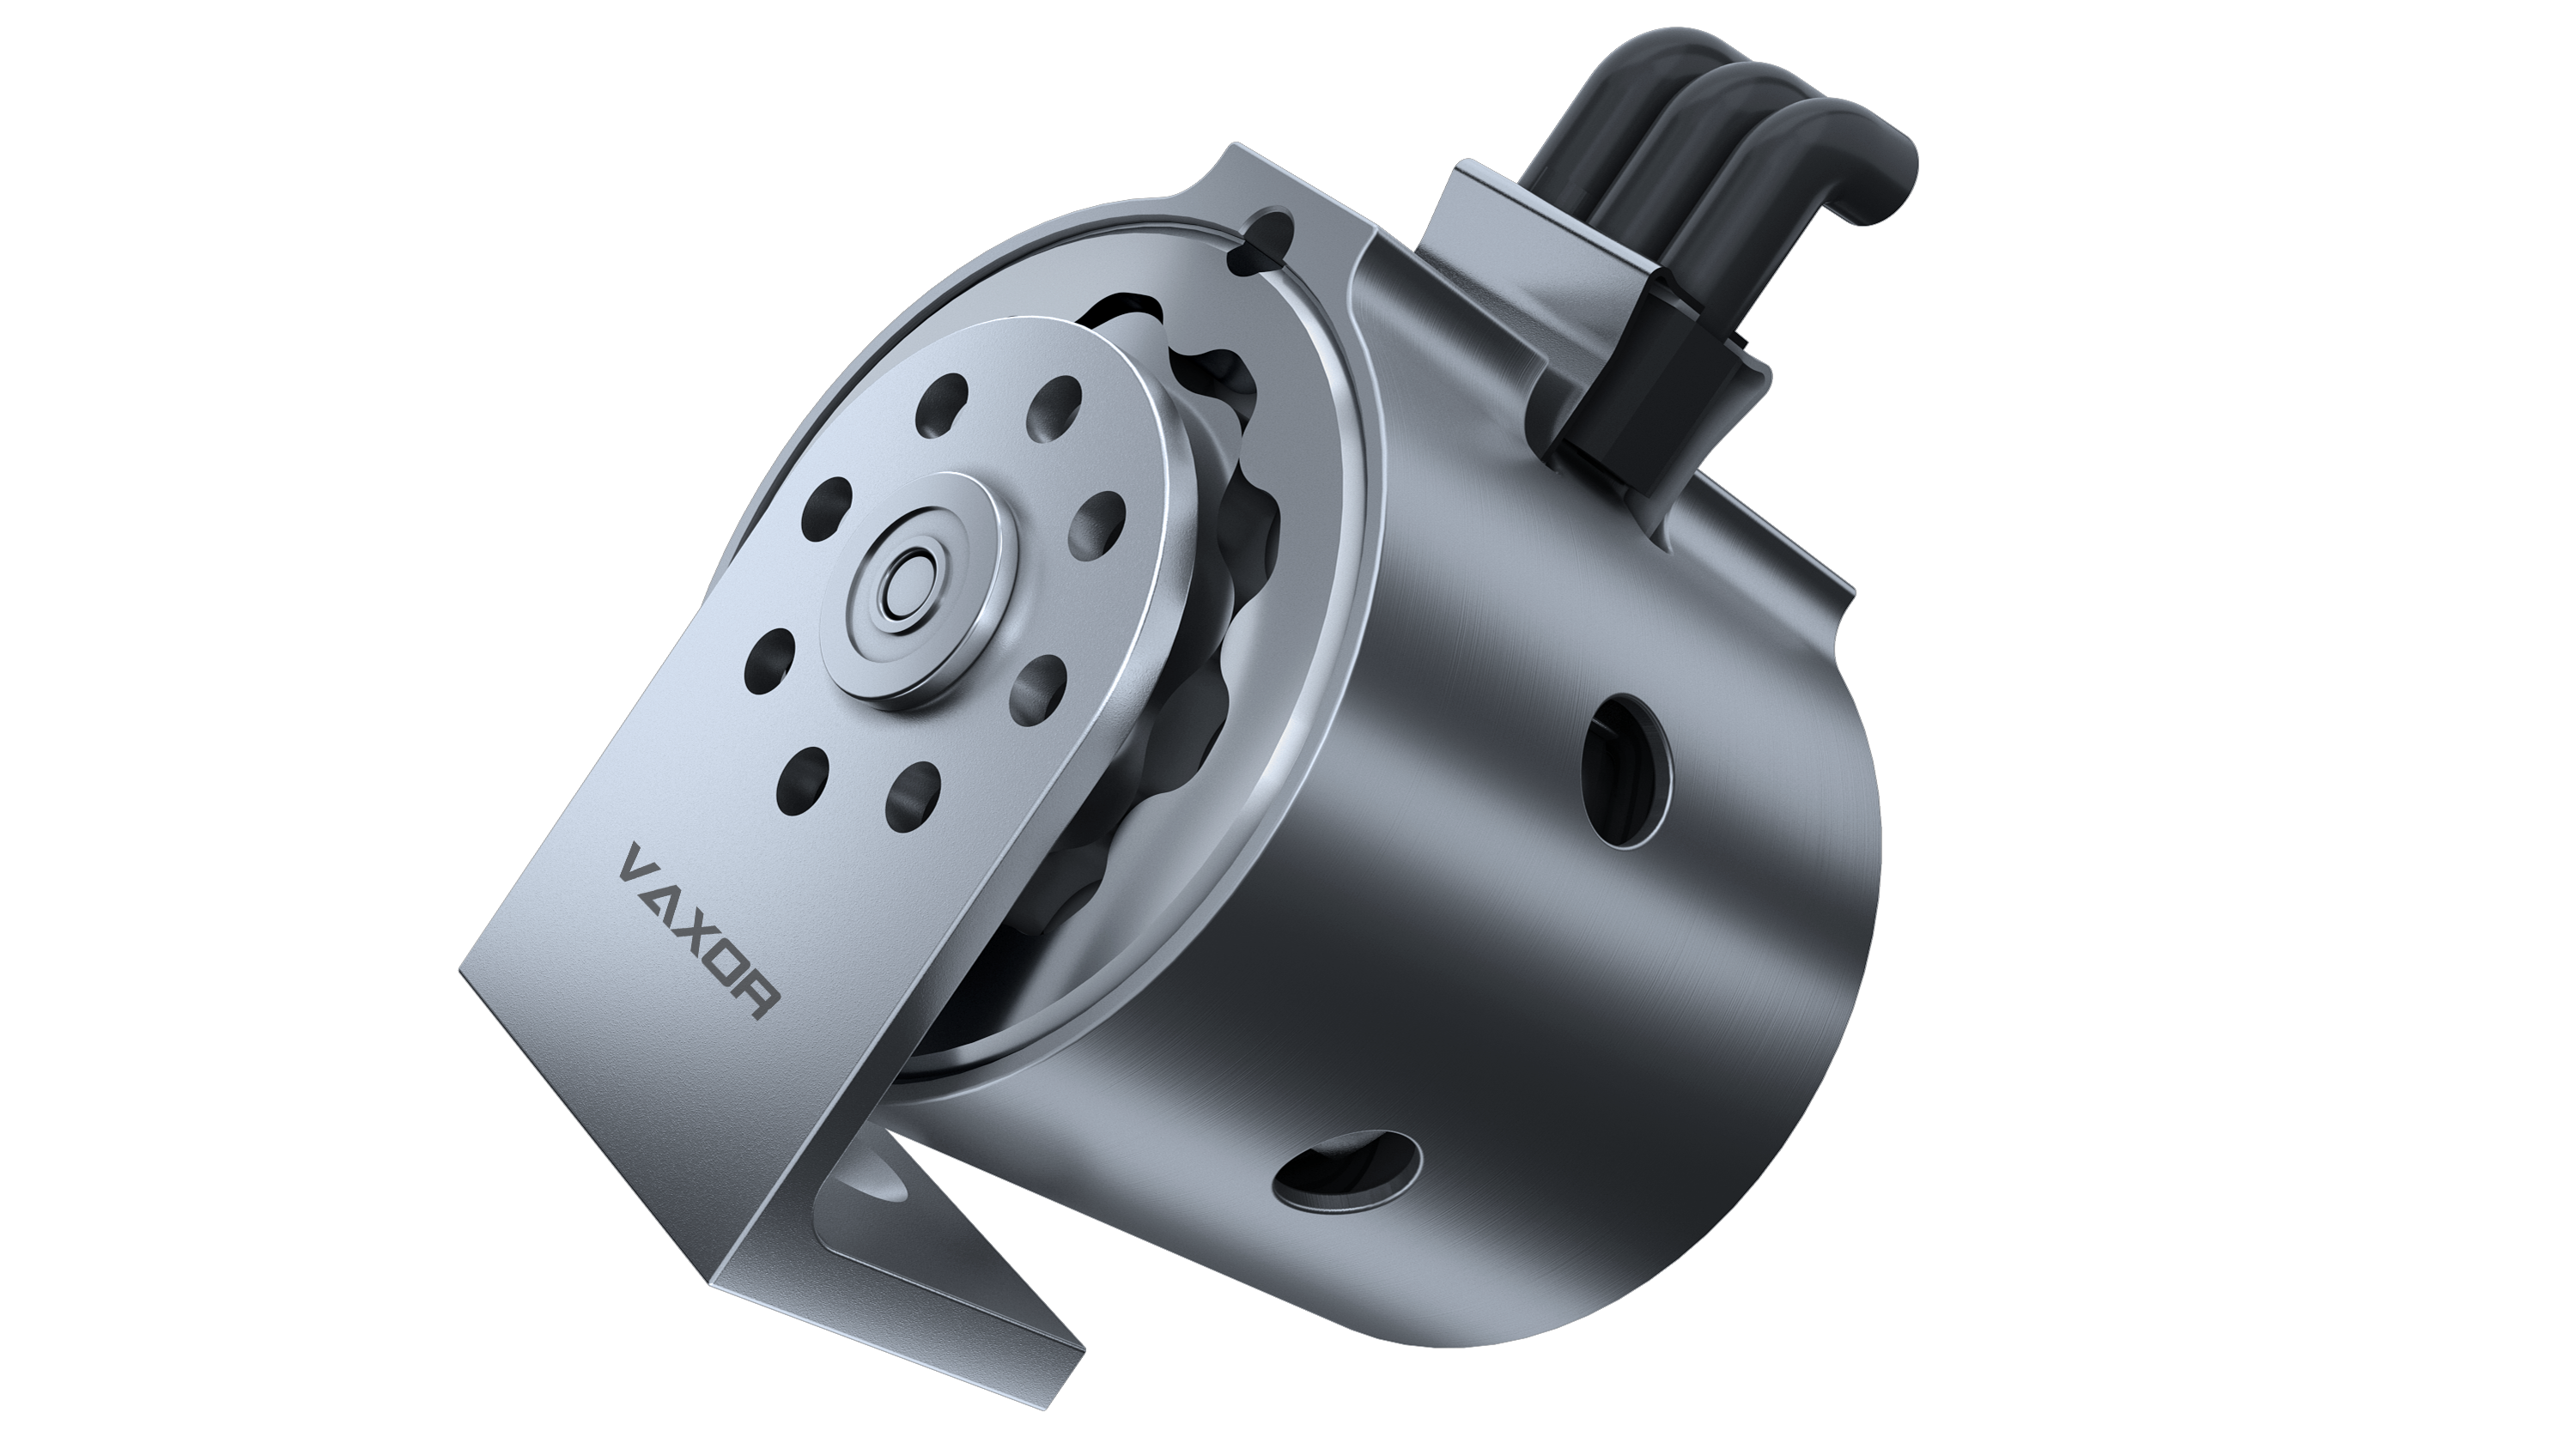
Understanding the Real Cost of Micro Robot Joint Actuators
Engineers designing dexterous robotic hands, bionic limbs, and compact automation systems consistently face the same challenge: how to source a micro robot joint actuator that delivers sufficient torque density and positioning accuracy without inflating unit cost. The core of this cost equation is manufacturing yield. Sub-6mm motor production has historically suffered from high cost and low yield, largely because electromagnetic imbalance in ultra-small windings drives up rejection rates and drives down consistency. VAXOR-MOTOR, operating under the AXOR brand, positions itself as a provider of integrated micro-actuation solutions built specifically to address this pain point—specializing in axial flux motors, micro cycloidal gear reducers, and non-contact encoder integration for high-load robotic and industrial applications worldwide.
Engineering Design That Controls Cost Without Sacrificing Performance
The differentiated advantage behind VAXOR-MOTOR's approach is straightforward: high torque density and rigidity are achieved through the integration of axial flux motors and micro cycloidal reducers, while electromagnetic designs optimize phase imbalance to within 5%. Holding phase imbalance within this tight band directly supports higher yield and power density, which is the underlying mechanism by which cost efficiency is achieved at the component level rather than through cutting corners on materials or specifications. This modular design architecture, paired with optimized electromagnetic design for both brushless and coreless systems, allows the same engineering platform to scale across multiple actuator diameters—from Φ16mm to Φ30mm—rather than requiring a bespoke design for every application.
Modular Actuator Family: X16 to X30
The Micro Joint Actuator Modules product line is positioned for precision actuation in dexterous robotic hands, highly integrated robots, and general mechanical motion control. Four diameter classes make up this family:
- Φ16mm Micro Joint Module (X16S / X16L): Weighing as little as 24.3g (S-version) or 26.1g (L-version), this module delivers continuous stalling torque above 7.1 mNm and stalling torque (max) above 16.5 mNm. It is available with gear reduction ratios of 30, 40, and 50, and includes an integrated absolute magnetic encoder and SPI communication for low-latency control. Chassis temperature limits of 80°C, 115°C, or 145°C, depending on power loss, are engineered in to prevent overheating.
- Φ20mm Micro Joint Module (X20S / X20L): Built for medium-load precision actuation, this module produces continuous stalling torque above 17.2 mNm and stalling torque (max) above 35.3 mNm, with support for 12V, 24V, and 48V operation. Gearbox ratios of 15, 30, and 50 are offered, and at ratio 50 the assembly reaches stalling torque up to 450 mNm. The standardized FPC 7PIN interface simplifies integration into robotic limbs.
- Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ): Designed for high-torque industrial and medical robotics use, this module uses CAN FD protocol for robust communication and reaches continuous stalling torque up to 1150 mNm at ratio 50. Backlash is reduced to 15 Arcmin, and mechanical strength limits reach 1800 mNm in the initial torque cold-state condition, suitable for peak load scenarios.
- Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ): The premium option for heavy-duty micro-robotic applications, delivering continuous stalling torque up to 1500 mNm at ratio 50, with gear efficiency reaching 75% at ratio 30. CAN FD integration supports complex multi-joint network architectures, and total inertia of 30.4 gcm² provides stability under high-load motion.
Ultra-Micro Motor Series: G04P, G05P, G06P
For applications where the actuator itself is not required but a compact electromagnetic drive component is, VAXOR-MOTOR's G04P, G05P, and G06P series address the same underlying cost pain point—high cost and low yield in sub-6mm motor production—at the motor level. These units are ultra-lightweight, ranging from 1.7g to 3.75g, and reach no-load speeds of 55,000 to 63,000 RPM, making them suitable for micro-pumps and drones. Phase imbalance controlled within 5% is again the mechanism behind reduced costs and improved reliability. Terminal resistance as low as 1.6Ω improves electrical efficiency, and chassis temperature support up to 145°C ensures reliability in compact, high-performance environments. These motors are used in micro-surgical robots, precision optical adjustments in photonics, and miniature haptics and pumps in consumer electronics.
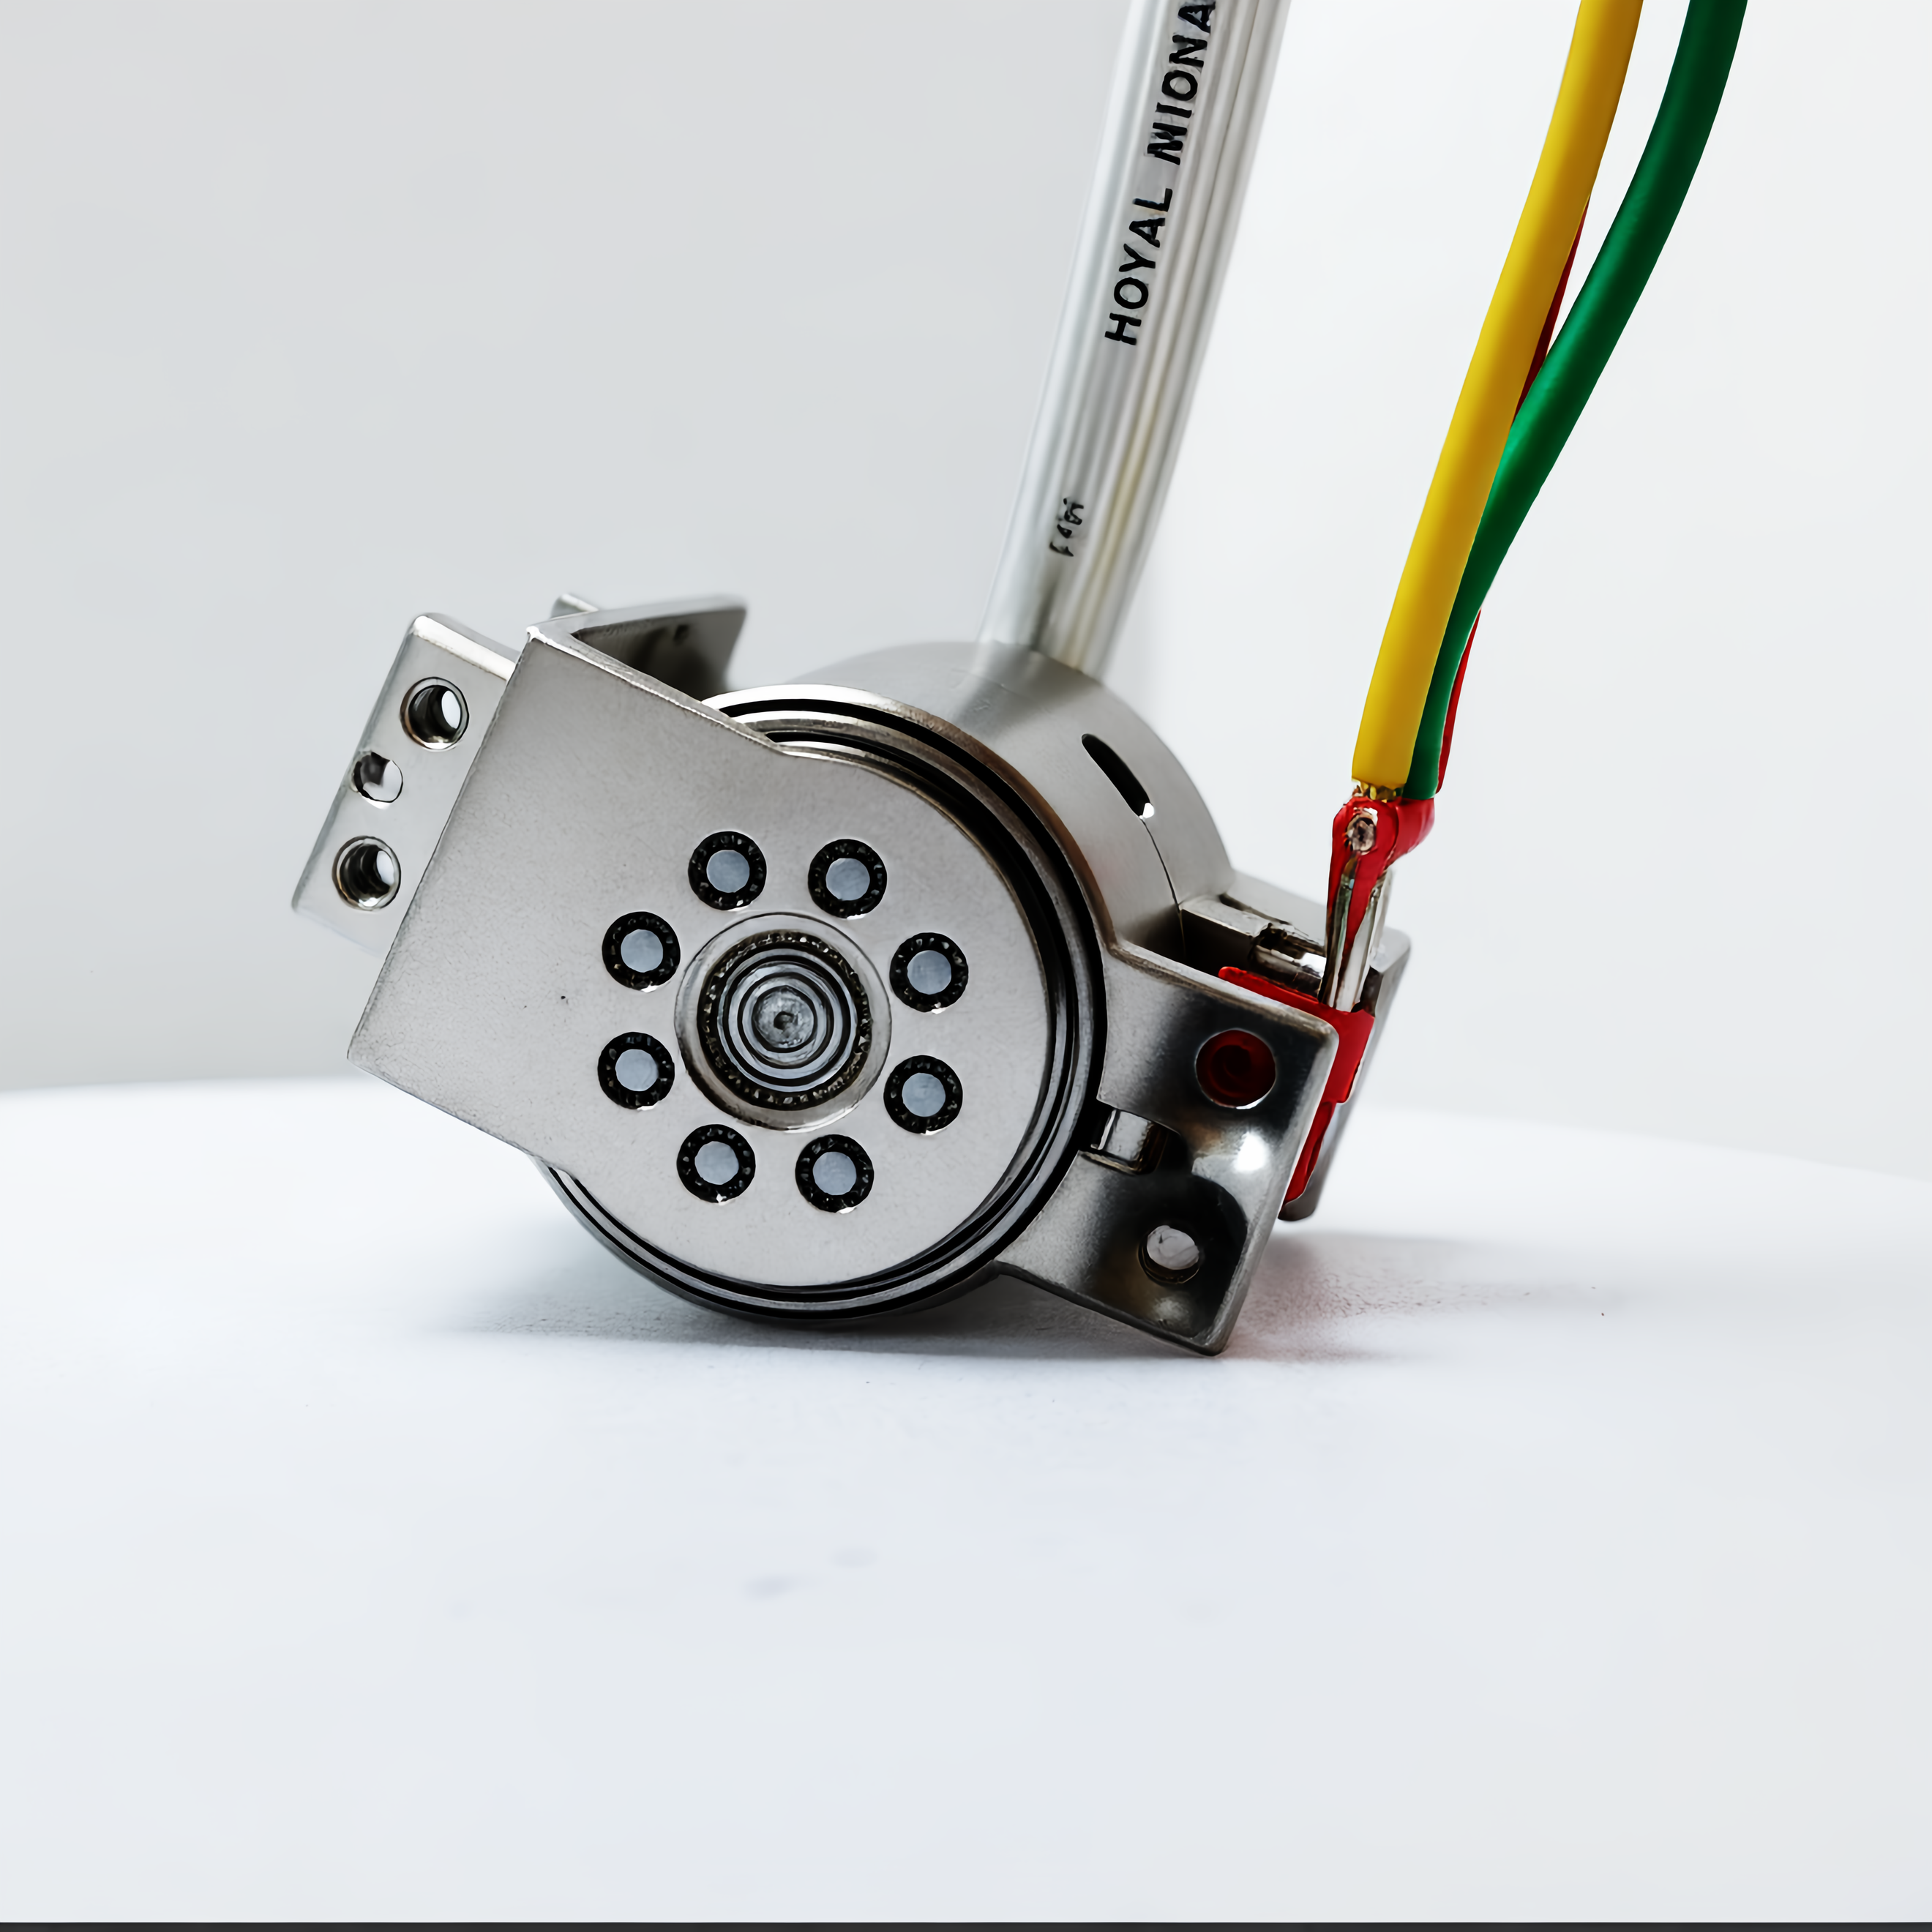
Platform Compatibility That Simplifies Integration Costs
Beyond the component-level engineering, total system cost is also influenced by how easily an actuator integrates into an existing electrical and communication architecture. VAXOR-MOTOR's platform supports 12V, 24V, and 48V DC bus systems, along with SPI and CAN FD communication protocols. The standardized FPC 7PIN interface, with 0.5mm pitch, carries VCC, GND, CS, SCK, MOSI, MISO, and a dedicated CAL calibration line—reducing the engineering overhead typically associated with custom wiring harnesses and non-standard communication bridges.
Business Model: Standardized, Product-Based Pricing
VAXOR-MOTOR's pricing approach is product-based sales for standardized modules across the X16, X20, X25, and X30 series, rather than fully customized quoting for every project. Deployment options include hardware integration through standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols, and after-sales support covers technical inquiries and discussions regarding product specifications and operational parameter ranges. Detailed technical specifications and test data—covering torque, speed, and thermal performance—are provided for electric drive assemblies, giving engineering teams the information needed to validate a module before committing to a design.
Where These Actuators Deliver Value
Across documented use cases, robotic dexterous hands have used X16 and X20 modules to achieve high-integration mechanical motion control for human-like finger dexterity. Industrial automation systems have integrated Φ30mm modules into precision transmission systems, achieving 75% gear efficiency and 15 Arcmin backlash. Micro pump systems have employed G05P ultra-micro motors running at 55,000 RPM for fluid transmission in medical and consumer applications, and photonics applications have applied ultra-micro brushless motors for precision positioning in optical instruments, benefiting from the sub-5% phase imbalance for stable performance.
For engineering teams evaluating micro robot joint actuator cost, the underlying takeaway is that cost efficiency in this category is not achieved through simplification, but through disciplined electromagnetic design, standardized modular architecture, and transparent technical documentation—an approach that VAXOR-MOTOR, through its AXOR product line, has structured its entire capability system around.
www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD.
About Author
